Projects & Experience
A full record of my engineering work: guidance, navigation & control and avionics research and flight hardware, the labs and organizations I've built it with, publications and patents, and the earlier projects and activities that got me here. For a condensed view, see my resume.
Guidance, Navigation & Control · Flight Dynamics
Research and coursework in controls, estimation, and flight dynamics, spanning hypersonic intercept guidance to thrust-vane rocket autopilots.
R&D Intern, Hypersonic Guidance, Navigation & Control
June 2025 – May 2026 Sandia National Laboratories · Albuquerque, New Mexico- Investigated multi-agent intercept dynamics for hypersonic and extra-long-range surface-to-air missile applications.
- Trained GNC deep reinforcement learning policies with PyTorch Proximal Policy Optimization (PPO) on NVIDIA A100/H100 GPU HPC nodes within a high-fidelity aerodynamics simulation environment.
- Evaluated multi-agent intercept scenarios against traditional ProNav control, raising intercept success by 30%.
Control Systems Engineer
August 2024 – May 2025 Georgia Tech Ramblin' Rocketry – Guidance, Navigation, and Controls · Atlanta, Georgia- Derived linearized state-space models of a thrust-vane TVC rocket across 200+ flight trim points for gain-scheduled control design.
- Automated trim-point refinement and A/B-matrix generation, eliminating 100+ hours of manual analysis.
- Developed, tuned, and tested LQR controllers in open- and closed-loop MATLAB simulation; implemented the design in C for an STM32 flight controller.
- Developed a static QUEST quaternion-estimation algorithm for launch-pad attitude determination and prototyped an Extended Kalman Filter (EKF) in simulation.
Georgia Tech Experimental Rocketry (GTXR)
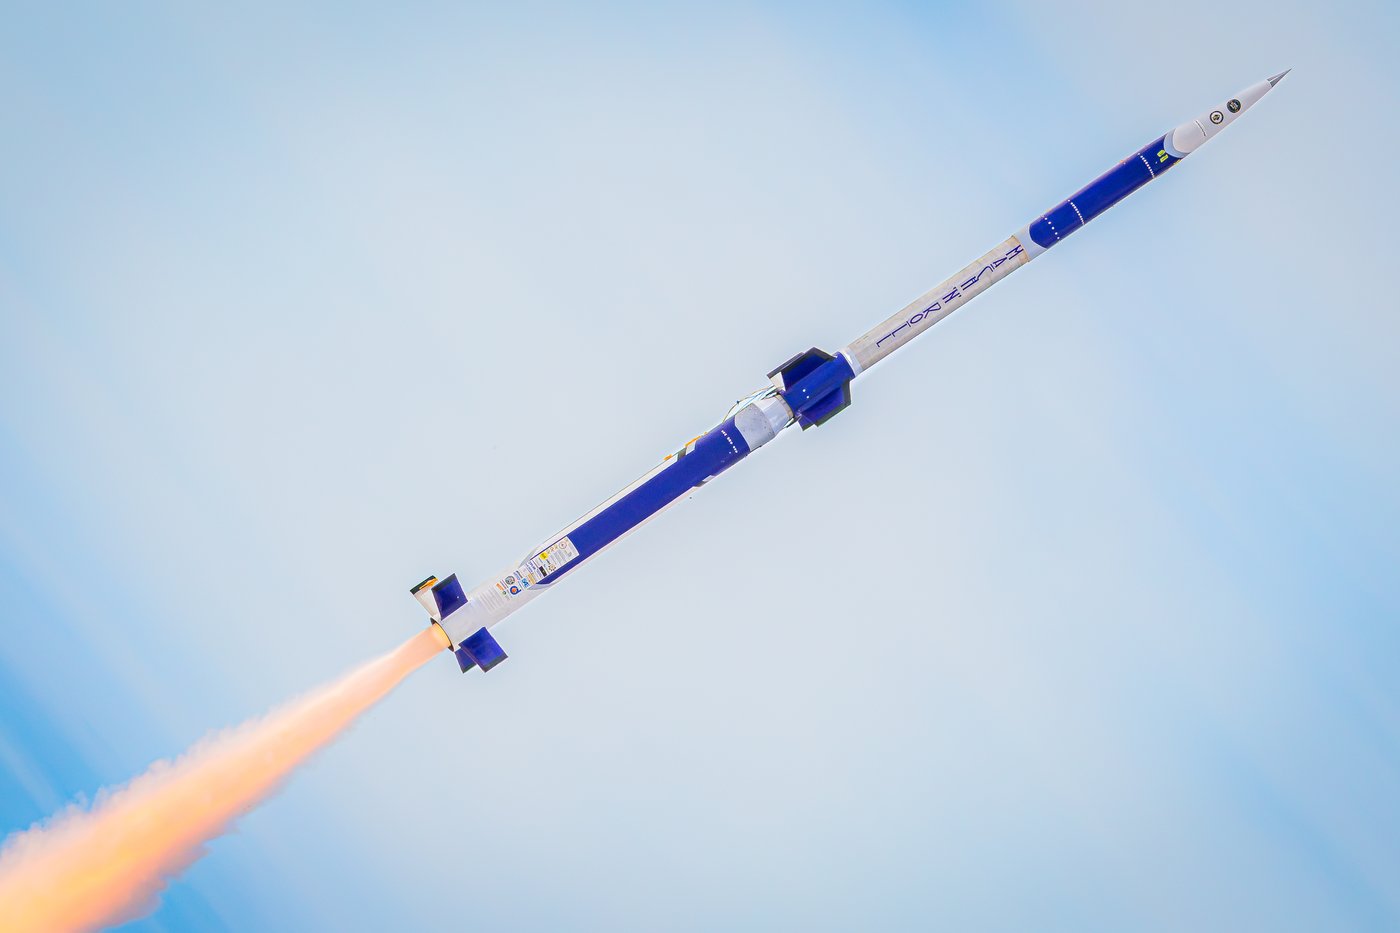
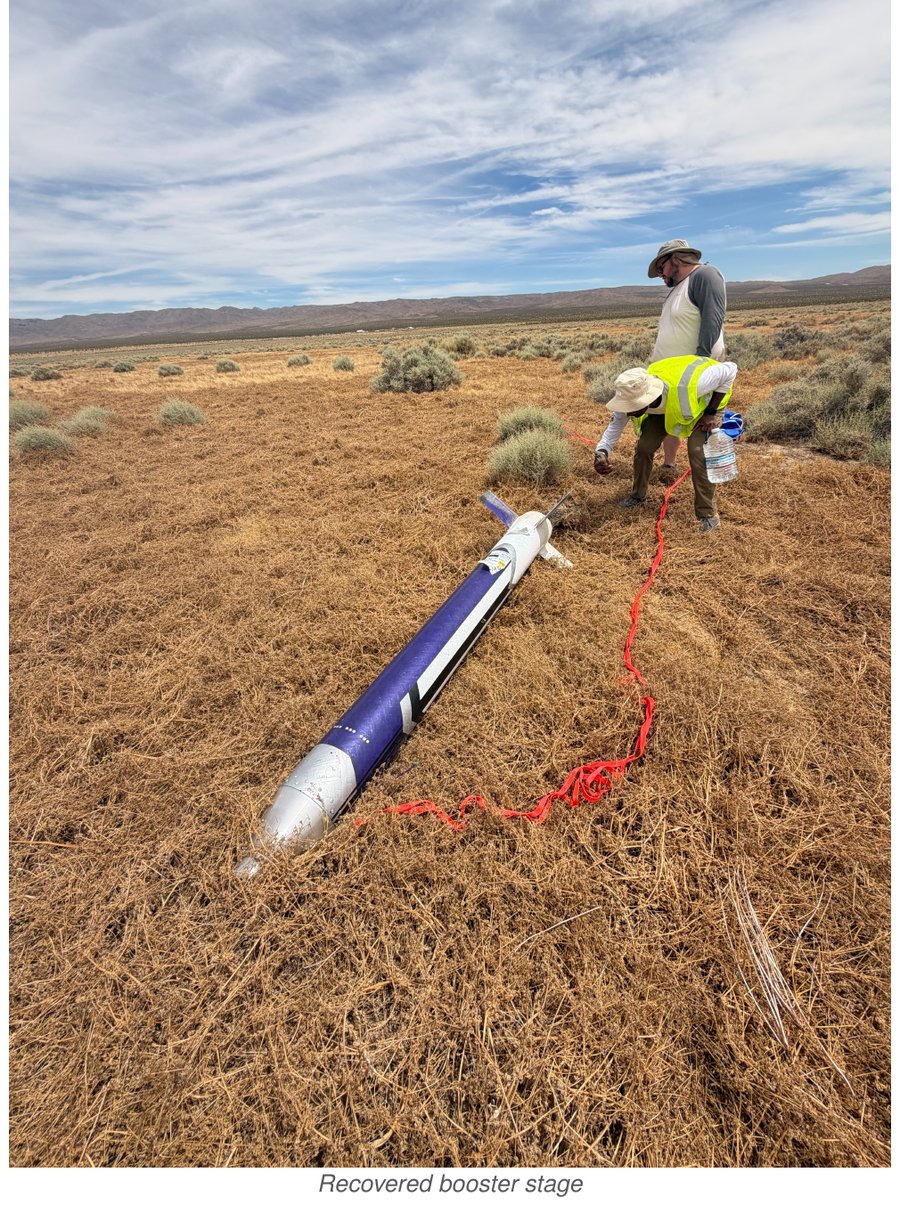
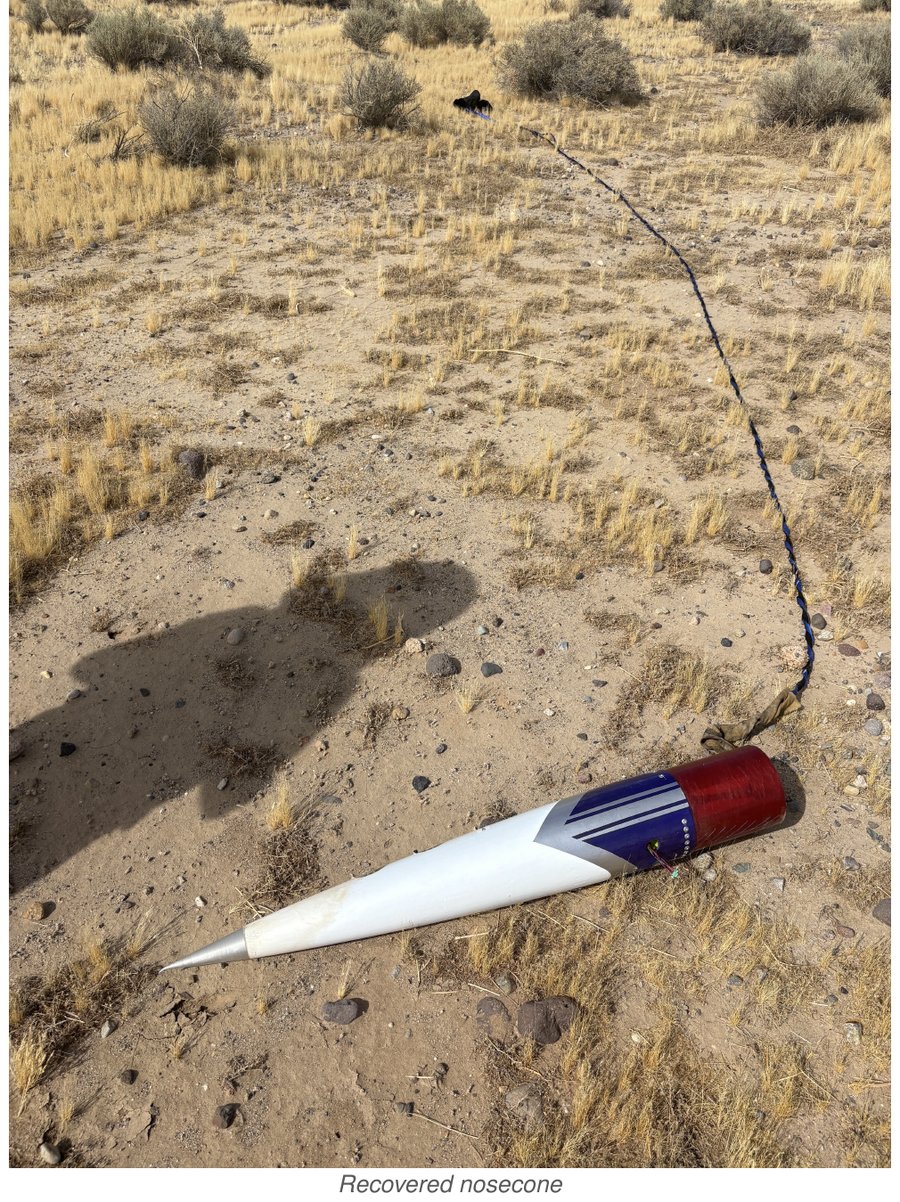
Four roles over two years, culminating in the July 2026 flight of Mach 'N' Roll — a 17-ft, 283-lb, two-stage rocket that reached a club-record 31,850-ft apogee with avionics that flew flawlessly on their first flight.
President
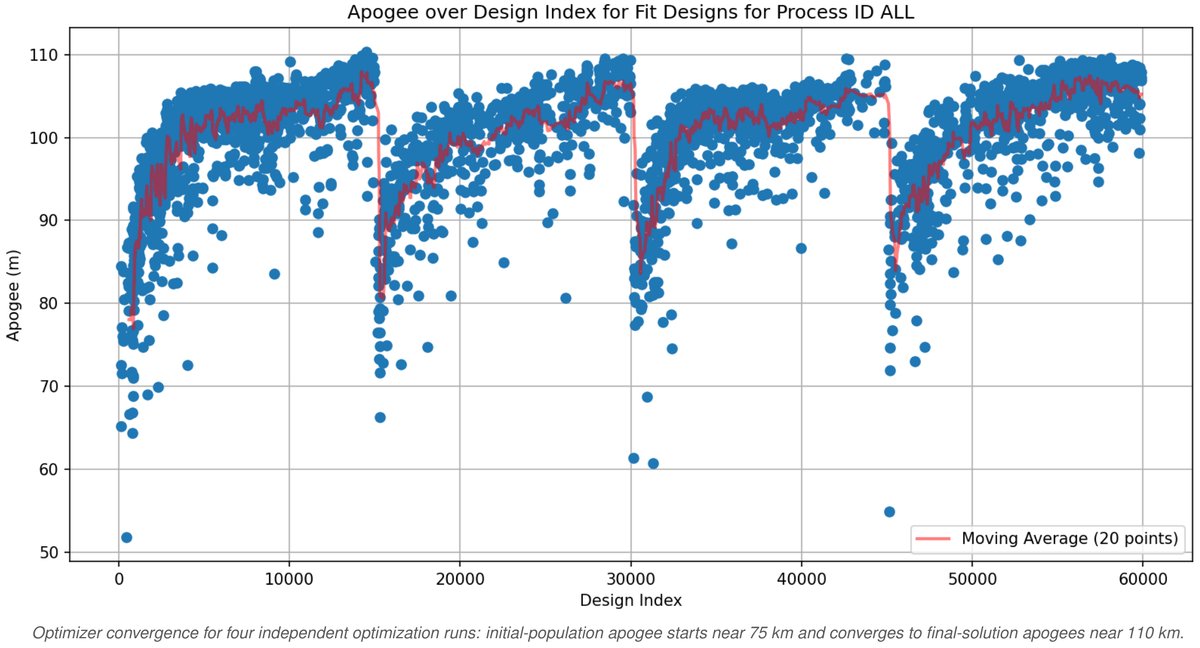
July 2025 – July 2026 100-member team- Optimized fin geometry and ignition delay for apogee via ant-colony/genetic optimization subject to 20+ flutter, stability, and manufacturing constraints in a custom 6-DOF RocketPy environment, evaluating 250,000+ designs in four days on GT PACE HPC.
- Modeled aerodynamics and rigid-body dynamics to characterize inertial roll coupling and set sustainer fin cant for intentional spin stabilization; flight data validated the strategy above and below the dangerous coupling frequency.
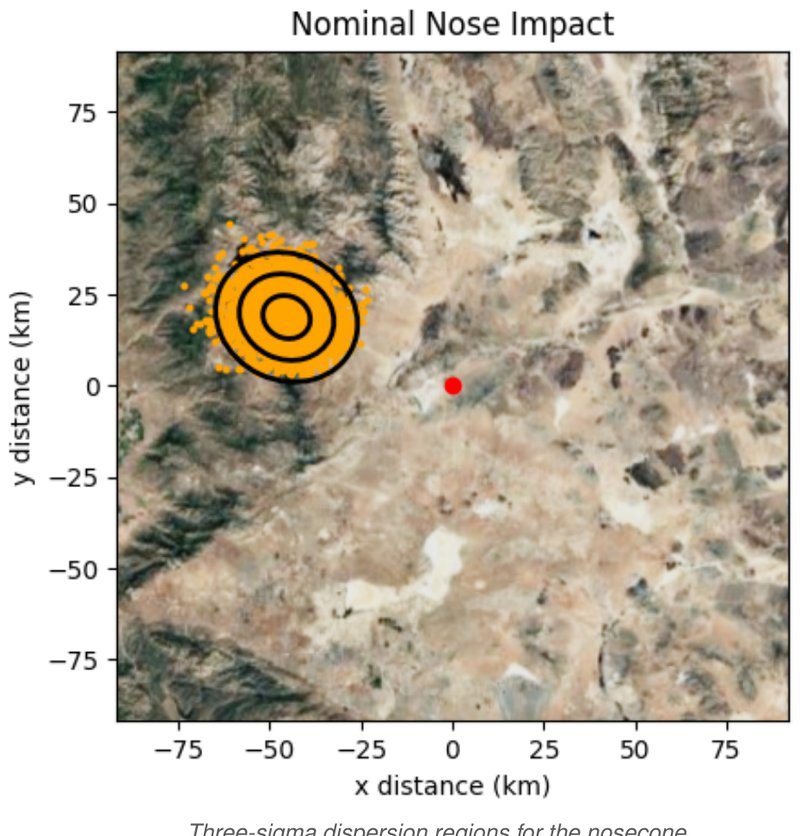
- Generated three-sigma recovery-dispersion regions from 2,000 Monte Carlo runs to plan launch-day recovery logistics.
- Led verification and validation (PDR, CDR, tolerance analysis, integration testing) and system-level trades for the full team.
- Managed and allocated the team budget across subteams and coordinated logistics and finances for 62 members.
Avionics Engineer
August 2024 – May 2026 Flight hardware, firmware, telemetry & ground software- Designed a 6-layer Attitude Determination and Control Systems (ADCS) PCB around an STM32H6 with onboard IMU, barometer, NAND flash, LoRa, GPS, CAN, microSD, JTAG, high-speed oscillator, and connector ESD protection in a PC104 form factor.
- Designed a custom DAQ PCB with safety-inhibit, reverse-polarity protection, and high-current DPAK MOSFET switching for pyrotechnic elements, integrating pressure transducers and e-match ignition with the NI CompactDAQ; designed a flight DAQ PCB for chamber-pressure and thermocouple acquisition.
- Designed Altium pyro/ignitor daughterboards for continuity monitoring and ignition, integrated with the flight computer over I2C/UART with CRC16 packet checking to reduce EMI-related data corruption.
- Built power/pyro shunt circuitry and umbilical harnessing for safe avionics handling during integration per FAR requirements; manufactured and validated two complete harness sets through subsystem-to-system integration testing.
- Developed bare-metal drivers and sensor-management software for IMUs, barometers, SD cards, ADCs, GPS, and XBee radios (UART, SPI, I2C, CAN, DMA, interrupts); developed and validated a quaternion strapdown attitude estimator that gates sustainer ignition.
- Designed a modular telemetry packet format and optimized RF link budgets for XBee and LoRa 915 MHz downlinks; built an ESD-safe flatsat test fixture and modular Python mission-control software (backend, middleware, multiple frontends) distributing telemetry via server-sent events.
- Hand-assembled and reflow-soldered PCBs under a microscope 20+ times, debugging with oscilloscopes and logic analyzers.
Propulsion Engineer
August 2024 – November 2025- Designed, analyzed, machined, assembled, and static-fired a novel 4-inch M-class solid-propellant rocket motor with an aerospike nozzle using SOLIDWORKS, hand calculations, ANSYS, manual milling/turning, and custom APCP BATES grains.
- Completed and validated 40+ ANSYS Static Structural, Fluent, and Transient Thermal analyses to evaluate structural and thermal factors of safety.
- Managed a 12-person engineering team, coordinating technical work to meet internal milestones for the solid-propellant aerospike motor program.
- Collected static-fire chamber-pressure data with NI DAQ hardware to characterize an APCP formulation incorporating oxamide as a burn-rate suppressant.
- Completed machine-shop training in manual milling, turning, and waterjet operation through the Georgia Tech Aerospace Machine Shop.
Data Acquisition System Lead
January 2025 – May 2025- Operated DAQ hardware and software for thrust-curve measurement during rocket-motor static fires.
- Designed a custom PCB to interface pressure transducers and e-match ignition with the NI CompactDAQ system.
- Streamlined ignition, sensor acquisition, and post-test analysis through a centralized PyQt6 dashboard (NumPy, Pandas, SciPy, Matplotlib).
Research Labs
Ongoing research assistantships spanning autonomous racing, urban air mobility tools, and rotorcraft CFD.
Undergraduate Research Assistant — F1Tenth Autonomous Racing
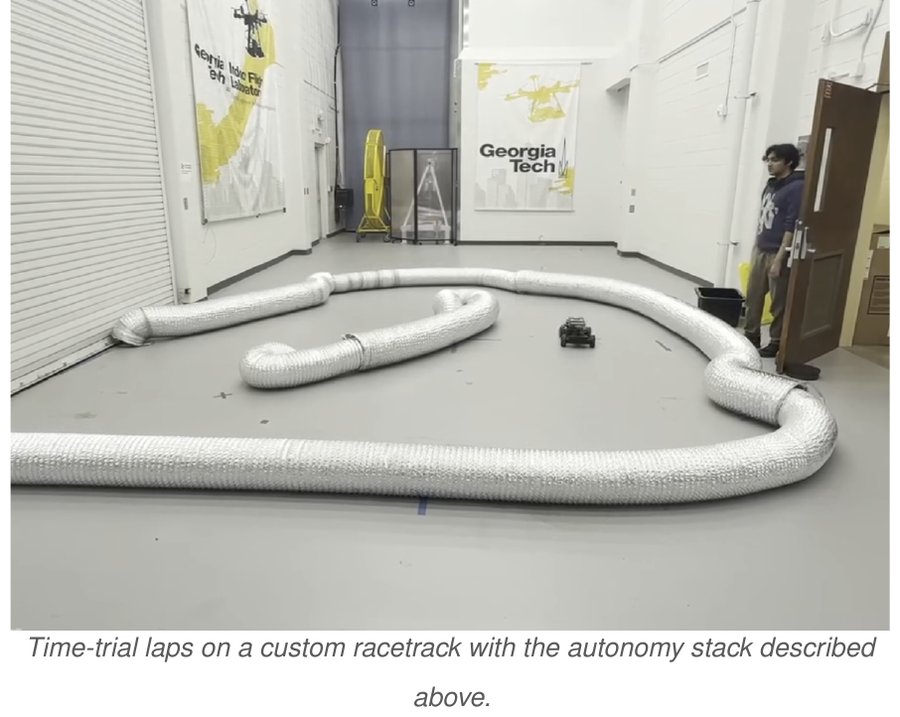
August 2024 – May 2025 Georgia Tech Dynamics and Control Systems Lab- Built an end-to-end autonomy stack for 1/10-scale racecars on NVIDIA Jetson Orin in Python, C++, ROS, Docker, and Ubuntu Linux — 2D LiDAR + odometry, SLAM with loop closing, offline racing-line optimization, Adaptive Monte Carlo Localization, and adaptive-lookahead pure pursuit — tested across two cyber-physical environments, demonstrating 10+ successful time-trial laps.
- Developed a disparity-extender reactive planner for dynamic environments using 2D LiDAR point clouds, and tuned odometry through physical testing (servo limits, turn radius, VESC RPM-to-speed gain).
Software Developer — NASA ULI IMOCAS
September 2024 – May 2026 Georgia Tech Nonlinear Computational Aeroelasticity Lab · part of the NASA ULI Innovative Manufacturing, Operation, and Certification of Advanced Structures for Civil Vertical Lift Vehicles (IMOCAS) team- Validated and debugged atmospheric-boundary-layer aerodynamic simulations using Mann and Dryden turbulence models for rotorcraft trajectories in urban environments.
- Built algorithms and UI for operational-analysis tools (flight planning, sensor analysis, environmental-hazard assessment) for urban-air-mobility VTOL operators, using a modular Python/PyQt5/C++ architecture (NumPy, Pandas, Matplotlib) with SOLID design principles.
Undergraduate / Incoming Graduate Research Assistant
August 2026 – Present CEREAL, Georgia Tech- Developing a real-time Lattice Boltzmann Method solver in C++/CUDA for mid-fidelity rotorcraft aerodynamics, including disk-actuator and disk-line rotor models and in-loop control systems.
- Benchmarking and optimizing simulation runtime on NVIDIA A100 GPU compute clusters.
Noteworthy Projects
Independent and coursework projects, from flight control design to deployed software.
DHC-2 Beaver Multi-Loop Autopilot
Avionics Integration Class Project · Simulink, MATLAB
- Developed a complete multi-loop autopilot in Simulink with inner-outer loop architectures for speed, bank angle, sideslip suppression, and altitude hold.
- Integrated an automated ILS glide-slope controller using coordinate tracking to hold a 2.5-degree descent toward the runway threshold.
- Tuned nested PID channels with anti-windup clamping and saturation blocks; determined trim at 80 and 90 kts and evaluated step responses, elevator deflection, angle of attack, and engine RPM.
- Built a quadruplex sensor-voting algorithm in MATLAB with dynamic outlier detection and automated disconnect thresholds for hard-over, soft-over, and oscillatory sensor failures.
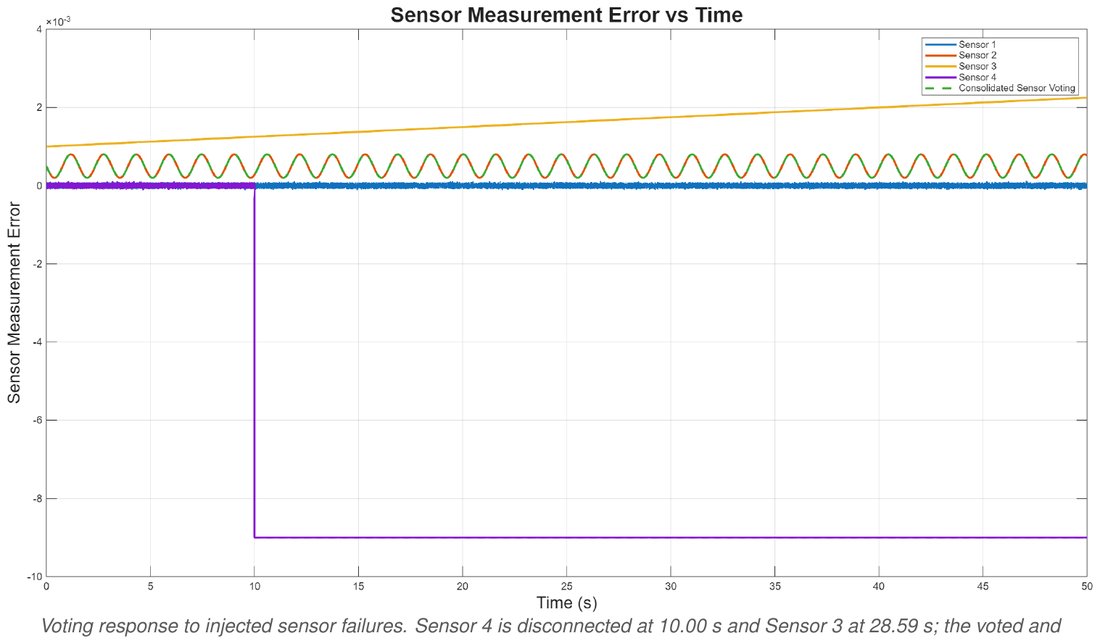
Voting response to injected sensor failures: Sensor 4 disconnects at 10.00s, Sensor 3 at 28.59s; the consolidated signal matches the good sensor with minimal error.
CHIMERA
Deep Reinforcement Learning, PyTorch, ONNX, Flask
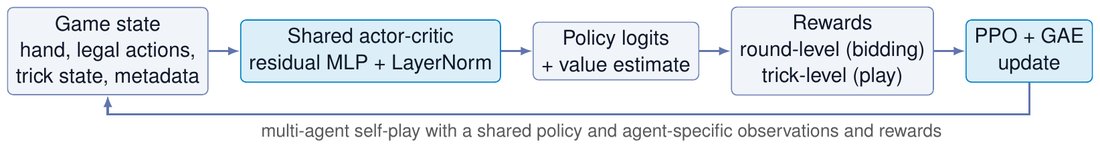
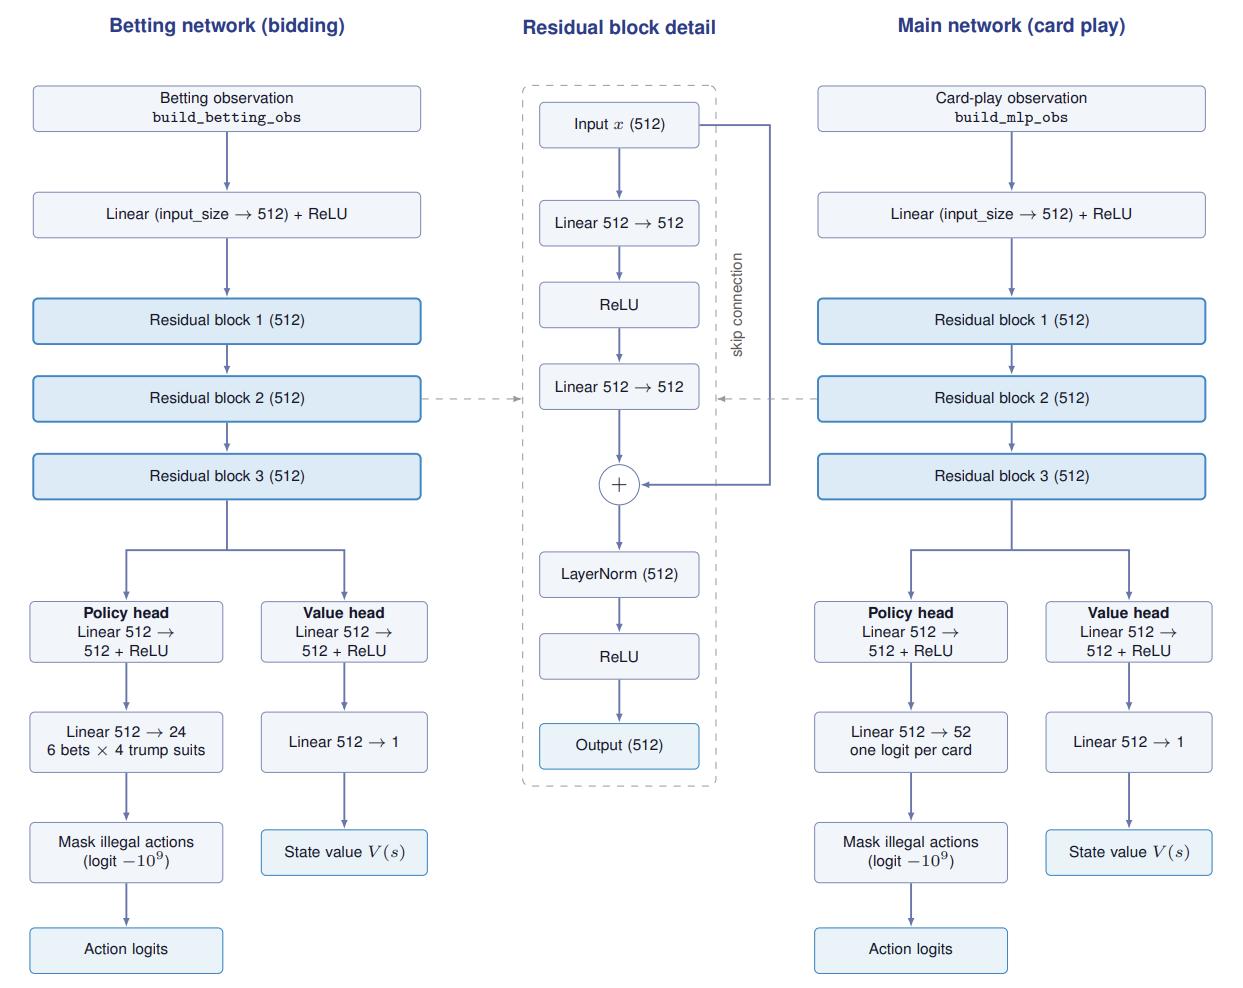
- Built a deep RL agent that learns 4-player Cinch trick-taking card game via multi-agent self-play using PPO with GAE (actor-critic, residual MLP + LayerNorm policy/value networks), eliminating hand-coded gameplay heuristics.
- Designed separate betting and card-play policies with round-level and trick-level rewards; beat experienced human players despite never playing humans during training.
- Exported trained PyTorch models to ONNX and built a Flask + Bootstrap web app with lazy-loaded Netron visualizations to play the agent and inspect its architecture; deployed serverless on Vercel (AWS Lambda).
Quizolytics
10/2022-01/2024
A natural language processer to analyze Quizbowl question datasets and extract meaningful insights from them.
- Determines the most common unigrams, bigrams, trigrams, and quadgrams throughout questions by calculating the PMI to evaluate the information carried by a certain n-gram.
- Handles 20,000 requests monthly using AWS Lambda serverless architecture.
- Built using Flask, HTML, Sass, JS, Vercel, and the QuizDB REST API.
Pymeasurement
02/2023-10/2023
A Python Measurement Calculator Library with Fixed Point Precision, Uncertainties, and Units.
- Expedites data analysis workflow for physics labs, chemistry labs, etc. by 5x.
- Designed using Object Oriented Programming for intuitive user experience and usage.
- Released to the Python Package Index (PyPi) and Read the Docs with 3000+ downloads worldwide.
Circuit Cracker
01/2023-02/2023
- A website to solve complex resistor circuits in any arrangement with logical reasoning.
- Designed as a Component Tree structure with recursive solving to determine the voltages, currents, and resistances for any complex circuit.
- Built using Flask, HTML, Sass, JS, and Vercel.
Publications & Patents
Publications
Modeling and Stability Analysis of Inertial Roll Coupling in Supersonic Sounding Rockets
Developed a compact dynamical model of inertial roll coupling using rigid-body rotational dynamics and linear aerodynamic restoring moments with coupled pitch–yaw equations; identified a bounded instability region and benchmarked against classical Mandell and LaBudde–Fetter formulations to support flight-dynamics trade studies for Mach 'N' Roll.
Read PaperDesign and Implementation of a Data Acquisition System for Rocket Motor Testing and Performance Analysis
Documented a rocket-motor DAQ architecture for real-time acquisition, transmission, storage, and analysis of pressure, load, and temperature data; used thrust variation and chamber-pressure anomalies to flag reliability issues before launch.
Read PaperPatents
Method for Determining a Magnitude of a Mass to Be Placed on a Wheel Assembly Using Acceleration Data
View PatentModular Mounting Apparatus for Determining Vehicle Vibrational Anomalies
View PatentMethod for Determining the Location to Place a Mass on a Wheel Assembly
View PatentMethod for Detecting Vibrational Anomalies of a Vehicle Using a Plurality of Devices That Are Removably Attachable to the Vehicle
View Patent ApplicationHonors & Awards
MathWorks Math Modeling (M3) Challenge — Semifinalist
Led a five-person team analyzing homelessness and housing data in two British regions (Python, Wolfram, MATLAB, NumPy, Pandas, Matplotlib, PyCaret, Seaborn, StatsModels); placed in the top 10 submissions among 800+ entries (~top 1%).
Wharton High School Data Science Competition — 2nd Place
Led a five-person team building ELO-based and machine-learning soccer playoff prediction models; placed 2nd among 300 teams from 37 countries and presented to sports analysts and University of Pennsylvania professors.
Sidney Goldin Scholarship — Recipient
Awarded for outstanding leadership abilities.
Early Experience & Leadership
Earlier internships, research, and leadership roles.
Senior Engineering Intern Manager / Physics & Data Analyst Intern — nth Solutions LLC | NVH Technology LLC
October 2022 – December 2024Managed a team of eight interns directing core R&D initiatives; contributed to IP development resulting in five or more patents. Applied Wavelet Transform, Vold-Kalman Filter, and Operational Modal Analysis to a removably-affixed tire balancer technology.
View WebsiteCo-founder — Tools for Intuitive Learning Experiences (TILE LLC)
June 2022 – June 2025Co-founded a software startup building technology-enabled learning tools; built an AdVenture Capitalist-style biochemistry game in Unity and Firebase Firestore teaching foundational biochemical pathways through incremental-progression gameplay.
Technology Specialist — 3 Tiny Bones
August 2021 – August 2024Developed an infinite-map dungeon crawler in Unity teaching students about noise hazards as part of a hearing-health awareness campaign, with custom enemy art and pathfinding/combat AI, deployed via WebGL. Maintained the nonprofit's website, improving traffic by 250% through analytics and SEO.
Software Developer — VEX Robotics (VEXMEN, Teams 91G & 91H)
August 2021 – May 2023Developed C++ driver-control and autonomous software for VEX V5 robots using PROS, including PID-tuned point-turn/drive control and custom encoder-based odometry; earned Tournament Finalist recognition and qualified for the state championship in both seasons.
Applied Mathematics Researcher — Delaware Valley Science Fair & Pennsylvania Junior Academy of Science
August 2017 – July 2024Five years of independent research spanning epidemiological modeling, traffic systems, game theory, and autonomous-vehicle applications; developed a SEIQRSD epidemic model and a game-theory/graph-theory traffic model using agent-based GPS navigation and system-level Q-learning signal control. Received Best in Mathematics / Director's Award multiple times and two research scholarships.
Citizen Scientist — EteRNA
May 2015 – July 2024Ranked in the top 0.5% of EteRNA players worldwide after nine years of RNA design and folding puzzle-solving; contributed RNA sequence designs used in research published in two Nature papers on synthetic RNA design.
Sensei — Code Ninjas
August 2022 – August 2023Taught Python, JavaScript, C#, and Scratch to K–12 students through one-on-one instruction and four themed coding camps, building individualized lesson plans and real-time debugging feedback.